Video: Synergies Between Affordance and Geometry: 6-DoF Grasp Detection via Implicit Representations
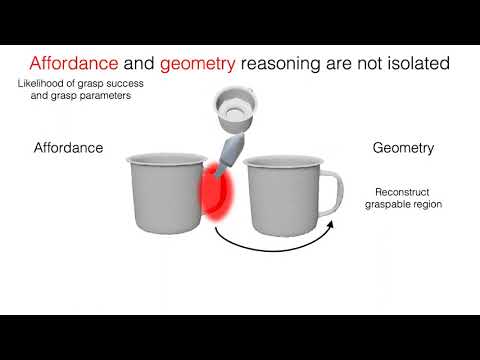
Video oleh UT-Austin Robot Perception and Learning Lab
Video oleh UT-Austin Robot Perception and Learning Lab
(PDF) Cooperative autonomous search, grasping, adalah layanan digital yang dirancang untuk membantu pengguna mendapatkan informasi lengkap dan terpercaya. Anda dapat menggunakannya dengan mengunjungi situs resmi dan mengikuti panduan yang tersedia.
Ya, (PDF) Cooperative autonomous search, grasping, dapat diakses secara gratis oleh semua pengguna. Tidak ada biaya tersembunyi atau langganan yang diperlukan untuk menggunakan layanan dasar yang disediakan.
Untuk mendapatkan informasi terbaru tentang (PDF) Cooperative autonomous search, grasping,, Anda bisa mengunjungi halaman resmi kami secara berkala. Kami selalu memperbarui konten dengan informasi terkini dan terpercaya.